Cassie
Agility Robotics · United States · Salem · discontinued
Plates · credit and license on each
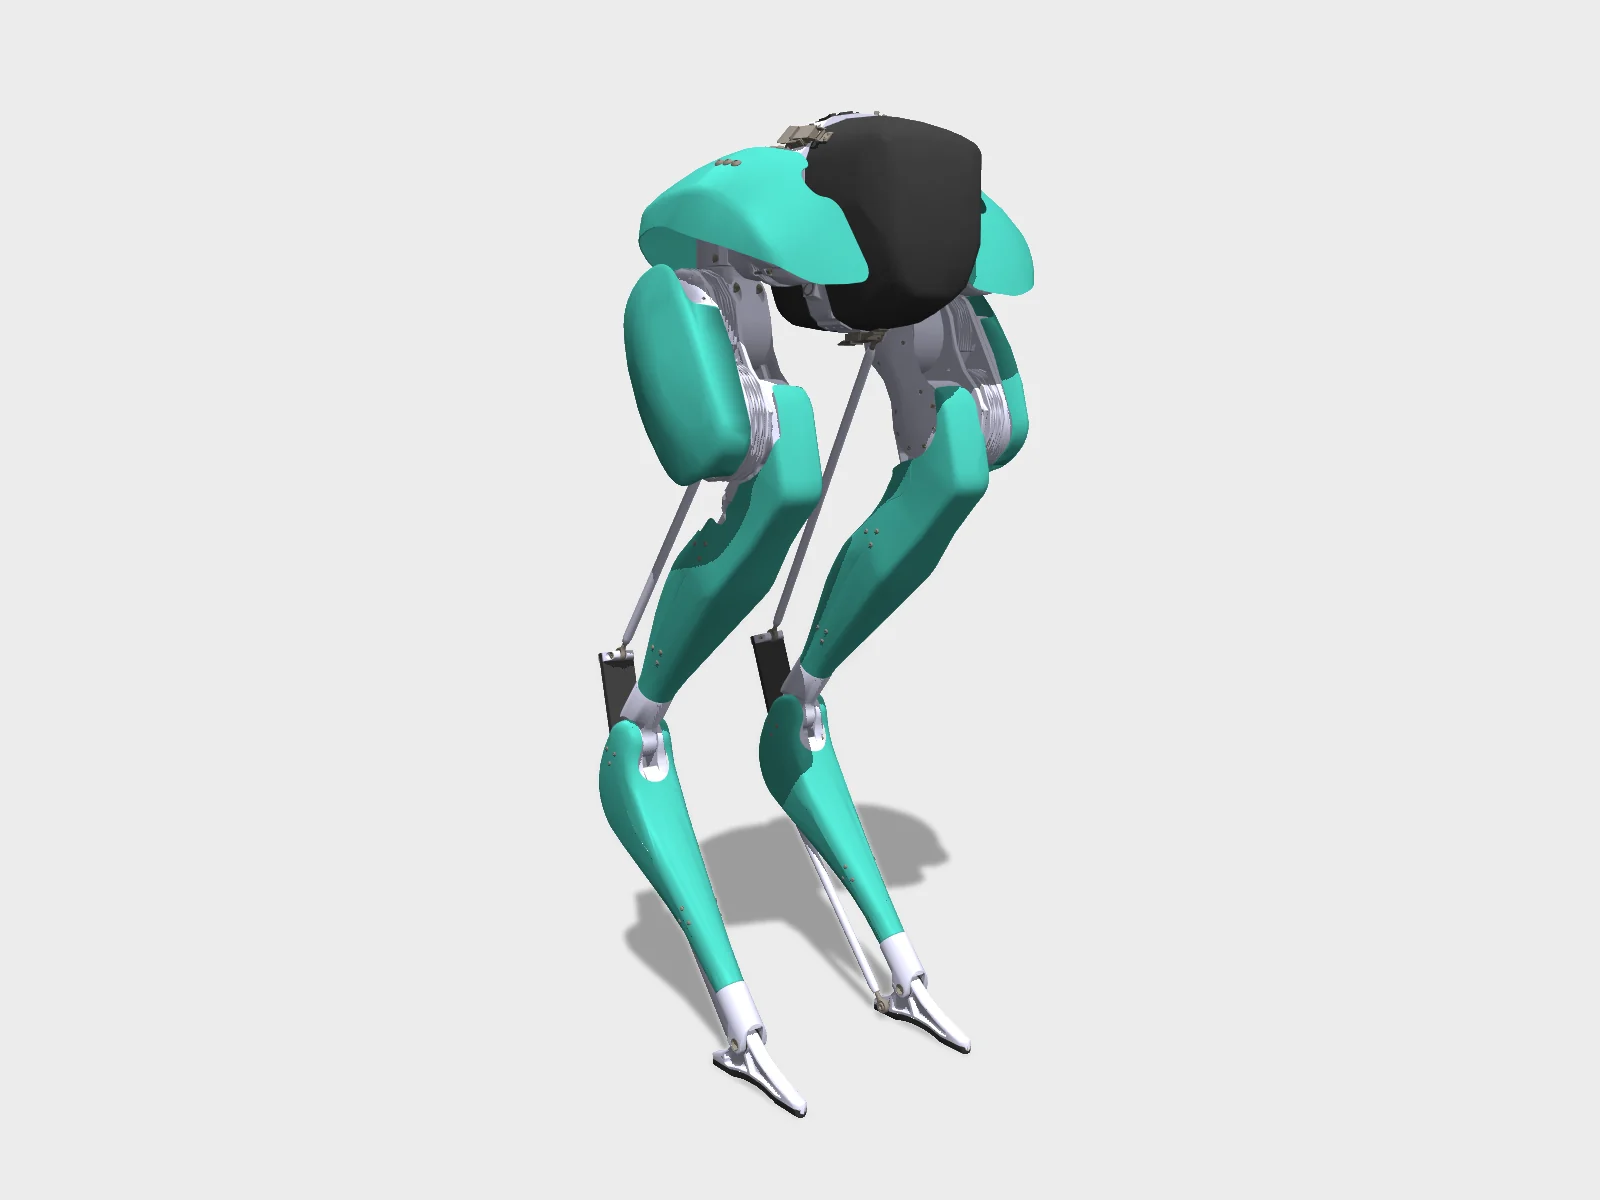
Studio render of the published MJCF, keyframe pose from the model. Geometry only; colours are the model's own materials.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 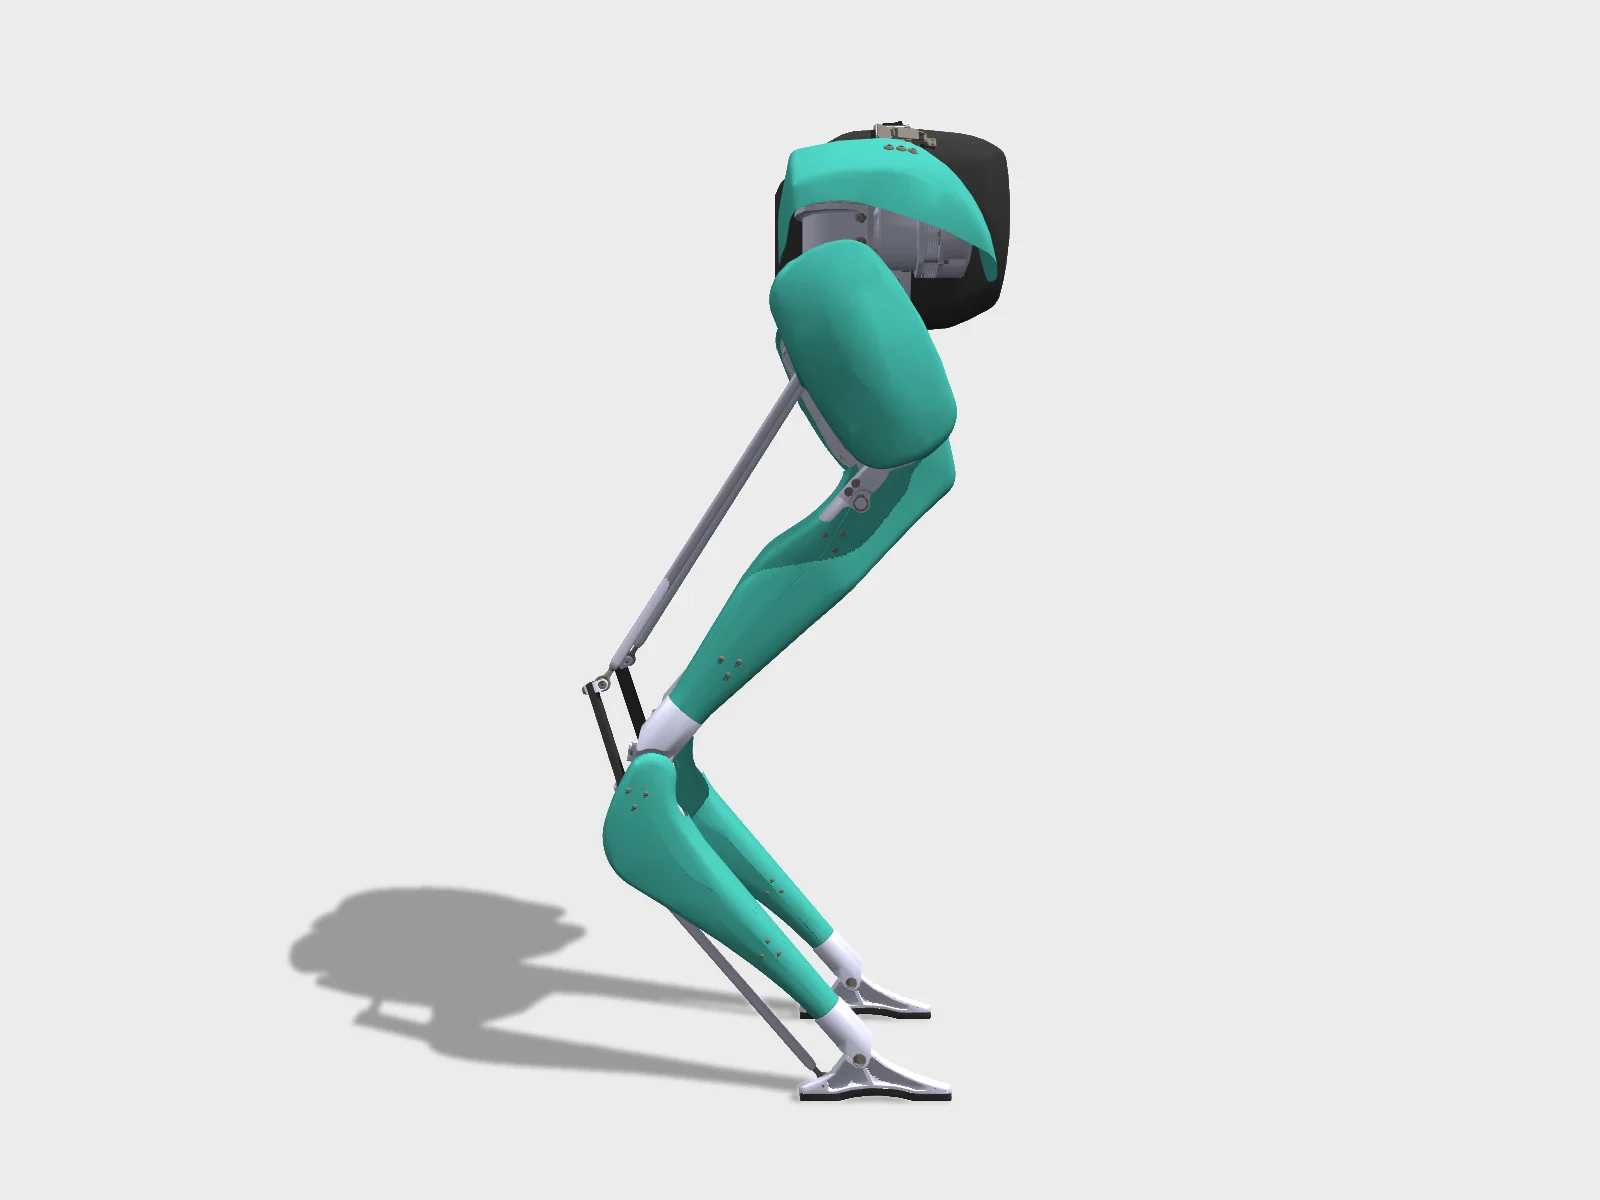
Side view of the same MJCF render, keyframe pose from the model.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 4 s turntable of the MJCF studio render.Rendered by Hyperspawn from mujoco_menagerie/agility_cassie (MIT) · Hyperspawn render · source 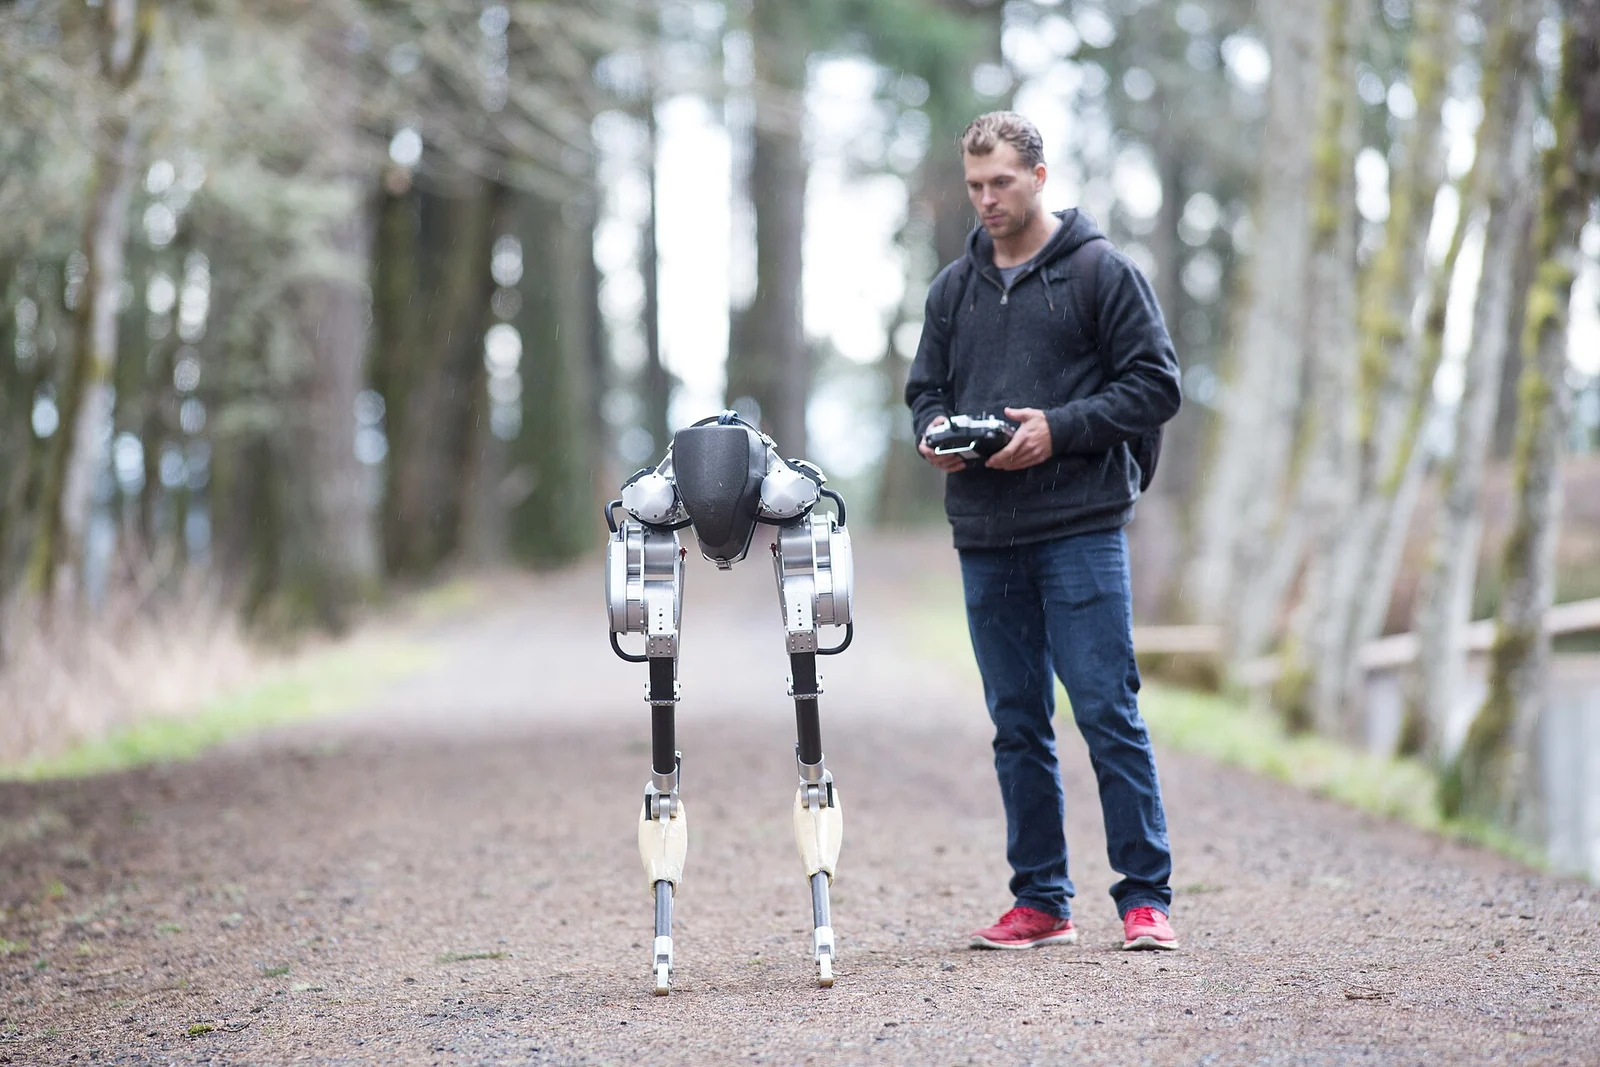
Via Wikimedia Commons (CC BY-SA 2.0).Oregon State University, via Wikimedia Commons · CC-BY-SA-2.0 · source 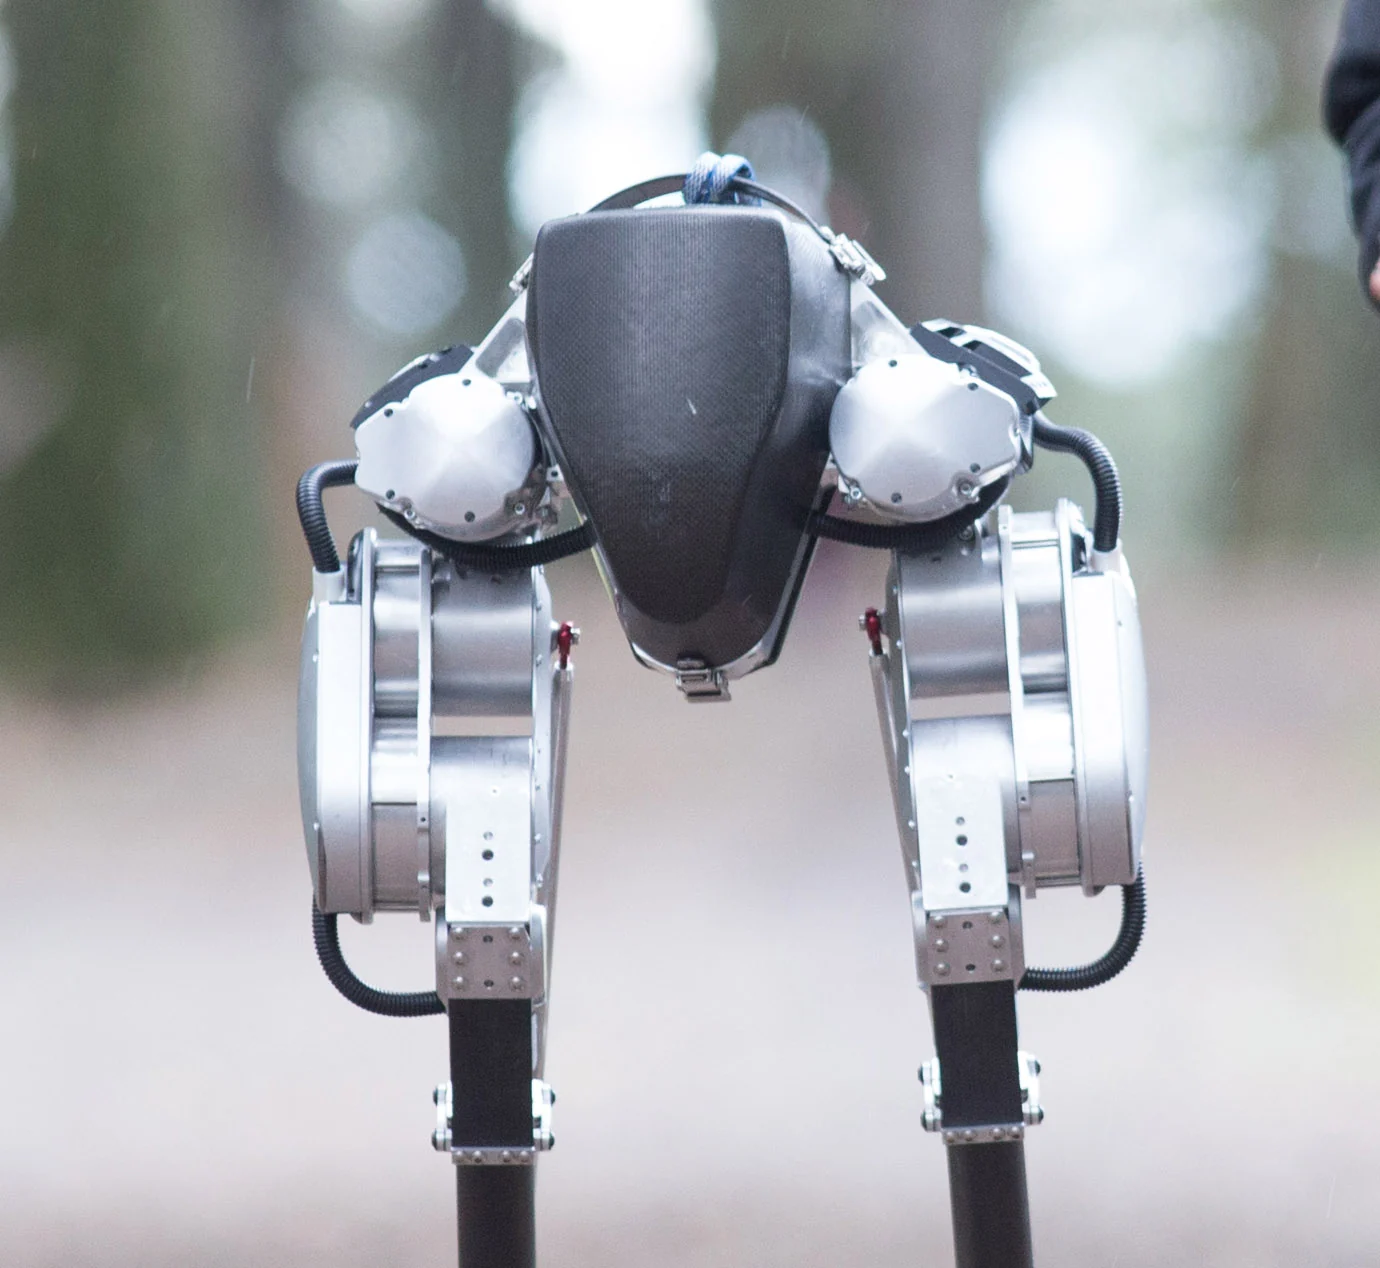
Via Wikimedia Commons (CC BY-SA 2.0).Oregon State University, via Wikimedia Commons · CC-BY-SA-2.0 · source Meet CassieAgility · official embed · source Cassie Sets World Record for 100M RunAgility · official embed · source


1 more on humanoidrobots.systems.
Not mapped
There is nothing here to light up.
No public units to map.. This map shows robots people build and run from open packages. Cassie is closed hardware, so there are no community builds to verify. If Agility Robotics opens it, it appears here.
humanoidrobots.systemsKnow it
humanoidrobot.buildBuild itclosed · Closed hardware; no public CAD or BOM.
humanoidrobots.trainingTrain ithumanoidrobots.teamFind its crewclosed · Not sold to individuals or labs.
humanoidrobots.earthSee it on the mapclosed · No public units to map.